ShenZhen Technology University
School of Artificial Intelligence
Arbeit Gruppe Dexterous Robotics
State and Parameter estimation for non-smooth
systems in robotics
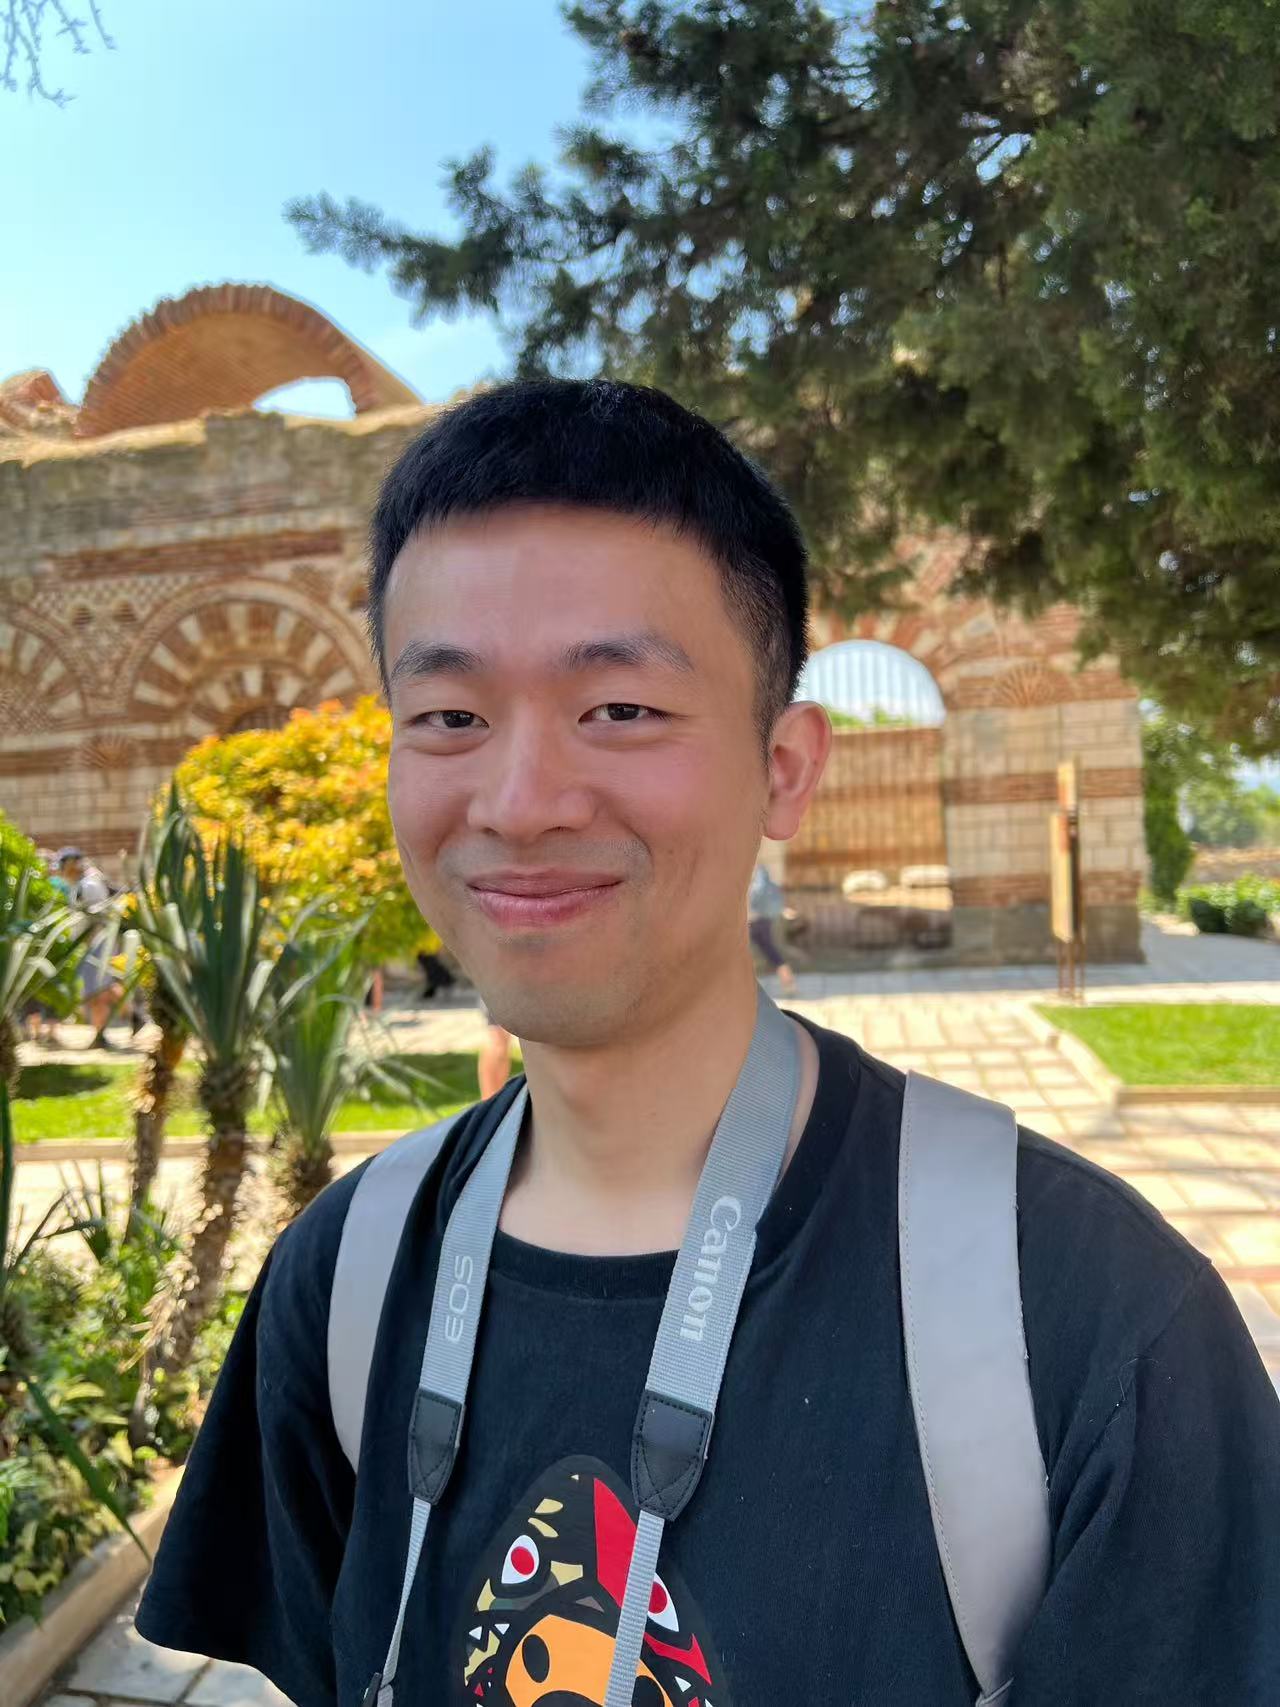
Jun-ning Huang (黄俊宁)
PhD Candidate
Technische Universität Darmstadt, Germany
Abstract
Friction and contact are fundamental nonsmooth phenomena underlying nearly all human and robotic interactions. To enable robots to perform human-like tasks, they must be able to sense and reason about friction and contact dynamics—either implicitly or explicitly. However, accurate estimation of these quantities remains challenging due to the complexity of frictional behavior, the nonlinear and multimodal nature of contact dynamics, and the reliance of existing methods on expensive force/torque sensing. In this talk, I would like to show how we address both friction and contact estimation purely from joint-space information, without external sensors. For friction estimation, we design a robust observer based on input-to-state stability and backstepping principles, avoiding parameter explosion while compensating for steady-state errors. The excitation design further exploits robot dynamic properties to decouple friction estimation across joints. For contact estimation, we decompose the problem into localization and force estimation. Using a hierarchical discrete flow-matching framework, we split the contact localization problem as robot link classification and localization on given links. The framework allows us to guarantee the feasibility of contact localization during inference and capture the multi-modality of the optimization problem. Finally, an improved disturbance observer enhances external torque estimation, boosting the precision of localization in a SLAM task. This unified treatment of friction and contact estimation provides a foundation for robots to achieve more adaptive and physically grounded interaction in unstructured environments.
Speaker
Junning Huang joined the Intelligent Autonomous Systems Group at TU Darmstadt as a PhD researcher in November 2020. He works with Davide Tateo and Jan Peters within IAS and its research group Safe and Reliable Robot Learning. Before joining IAS, Junning received his bachelor's degree in Microelectronics, as well as his master's degree in Computer Science from the Guangdong University of Technology. During his studies, he focused on two topics in reinforcement learning (RL): efficient exploration and applications in autonomous driving. His current research interest lays in three folds: 1. State Estimation / System Identification for Non-smooth Phenomenon including: Friction, Contacts, Deformation; 2. Compliant / Passive Control for Contact Rich Environment; 3. Trajectory Optimization for Contact Rich Environment; with applications on robots.
All are welcome!